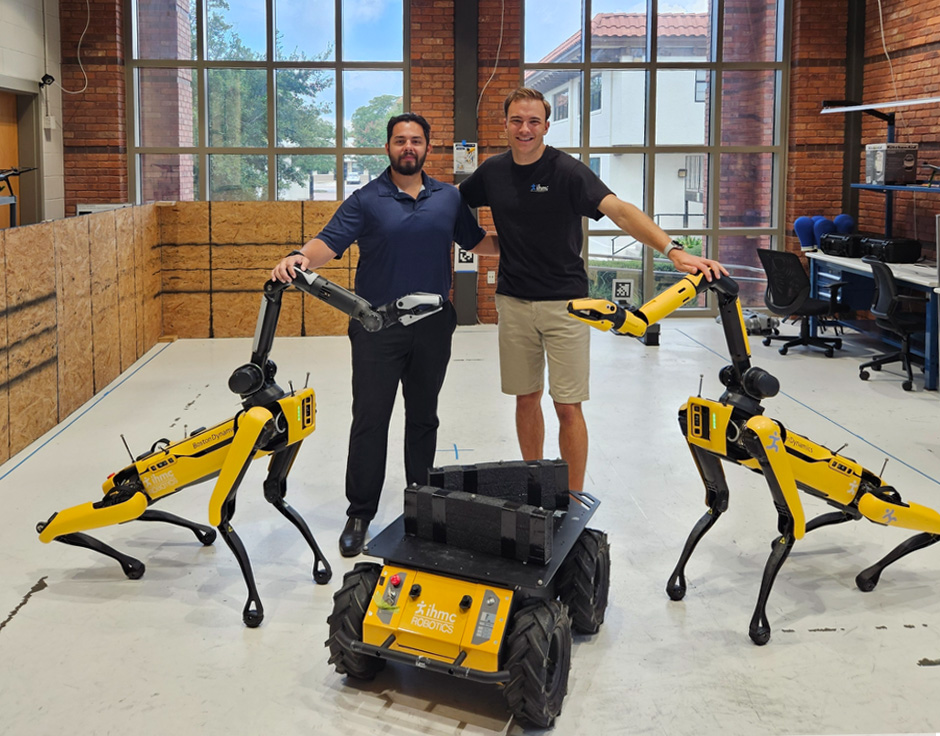
Robin Lange wraps up a productive summer as an NCCA intern, seen here with his advisor Dr. Nino. Robin spear headed the initial integration of our first NCCA platforms. Robin worked to integrate the NCCA's Boston Dynamics Spot robots into the IHMC robotics development environment. He set up an integrated a motion capture system and worked with Dr. Nino to get a visualization and control user interface working. All of his efforts over the summer culminated in a cool demo of two Spot platforms collecting objects and loading them onto a Husky platform.